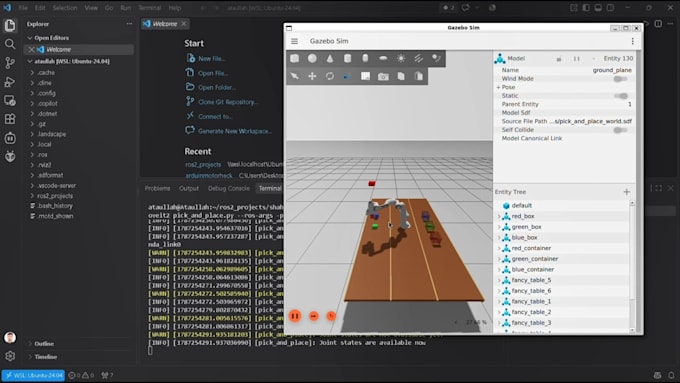
Need to validate your robot's kinematics or debug a broken URDF before touching real hardware? I build clean, verified robotics modeling and simulation pipelines in ROS 2, Webots, and Pinocchio.
What I Deliver:
- URDF / Xacro Modeling: CAD-to-URDF conversion with accurate inertia, joint limits, and RViz2 launch files.
- FK & IK Solvers: Analytical and numerical kinematics (6-DOF & 7-DOF) in Python (Pinocchio) or MATLAB.
- ROS 2 & Webots Integration: Complete colcon-ready workspaces with ros2_control, TF2 trees, and trajectory verification.
Why Choose Me?
- Clean, modular code tested on Ubuntu/WSL with clear README setup instructions.
- Every delivery includes a recorded simulation video proving smooth joint tracking.
- Message me with your robot specs or CAD files before ordering to confirm scope.